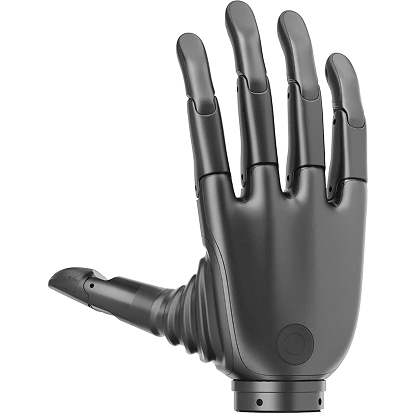
BrainCo Revo 3 Industrial Dexterous Hand FAQ
Which communication protocols does the Revo 3 support?
The Revo 3 Industrial Dexterous Hand supports Modbus-RTU over RS485 and CAN FD (in development).
Revo 3 has 21 built-in motors. What are the power supply recommendations?
Since the Revo 3 integrates 21 independent motors, the instantaneous current can be relatively high under heavy loads or when multiple fingers move simultaneously. Use a stable 24V industrial-grade DC power supply with a power rating of at least 100W to reduce the risk of voltage drops that could trigger host processor resets.
How is the latency when controlling 21 motors?
The default baud rate is 5 Mbps (5000000 bps). Command writes and status reads are designed for 21 motors.
Does the Revo 3 support auto-calibration?
Yes, it does. After powering on the Revo 3, you can trigger auto-calibration by short-pressing the back button or sending Modbus register commands. Each finger will execute a home sweep to find the absolute physical limit bounds and establish its absolute zero position.
What are the units for position, velocity, and current control?
The physical quantity definitions are consistent with the BrainCo dexterous hand family:
- Position: 0.1 degree
- Velocity: 1 degree/second
- Current: mA
How do I identify my dexterous hand model and configuration from the device Serial Number (SN)?
Every BrainCo dexterous hand has a unique Serial Number (SN) labeled on the device surface or readable via the SDK interface. For the Revo 3 series, the SN prefix strictly follows this modular encoding scheme:
BC [DOF_letter] [Touch_letter] [Side] [Version]
Revo 3 SN Prefix Structure Analysis
BCUB / T / VL / RV3
Detailed SN Prefix Segments
BC
Brand Identifier: Fixed prefix abbreviation exclusively for BrainCo dexterous hands.
DOF
Active DoF / Motor Count Classification:
U Revo 3 standard configuration with 21 DoF / 21 motorsTouch
Tactile Sensor Categories:
B No tactile modules (No Touch / Basic)T Piezoresistive tactile array modules (Tactile)V Vision-tactile sensor module (Vision-Tactile)Side
Hand Laterality:
L Left HandR Right HandVer
Hardware SKU Version: Identifies the hardware SKU of the device. The SDK resolves this code to load the correct Modbus register map and motion safety profiles for the matching SKU:
V3 Revo 3 SKU (21 DoF, default 5 Mbps)V2 Revo 2 SKU (Previous 6 DoF version, default 115200 bps)V1 Revo 1 SKU (Classic initial release)Encoding Parsing Example
For instance, if the SN string read from your device label or through the SDK interface is BCUTLV3xxxxxx, the intelligent decoding and data-stream loading workflow of the system is as follows:
Device SN Decoding & Data Stream Simulation
Input SN:BCUTLV3xxxxxx
BC════>Identified as BrainCo Biomimetic Hand
U════>Matched to 21 DoF / 21 Motor configuration
T════>Loaded Tactile Array Sensor Modules (388 points)
L════>Detected as Left Hand (L) Physical Laterality
V3════>Loaded Revo 3 SKU Kinematics & Protocol Configurations
[SUCCESS]Decoding complete: connecting to Revo 3 tactile left hand in 21-DoF mode.
💡 Developer Recommendation
When developing host-side applications, it is highly recommended to use the SDK's get_hardware_by_sn (C API stark_get_hardware_by_sn) function to dynamically fetch and apply the correct hand joint definitions and safety current limits, preventing out-of-bounds control commands caused by hardware version mismatch.
Contact & Support
📞 Contact for Support & Purchase
If you have any technical questions, integration questions, or customized/bulk purchase requirements, contact the BrainCo Dexterous Hand Technical Support Team, or submit a support ticket through the page help entry.